David Braun
Robotics · Control · Dynamics
I lead research and innovation in robotics technologies. This website is my academic research and teaching portfolio. I am also the founder of Adaptive Machines LLC and MindMotion, Inc.
Research
All research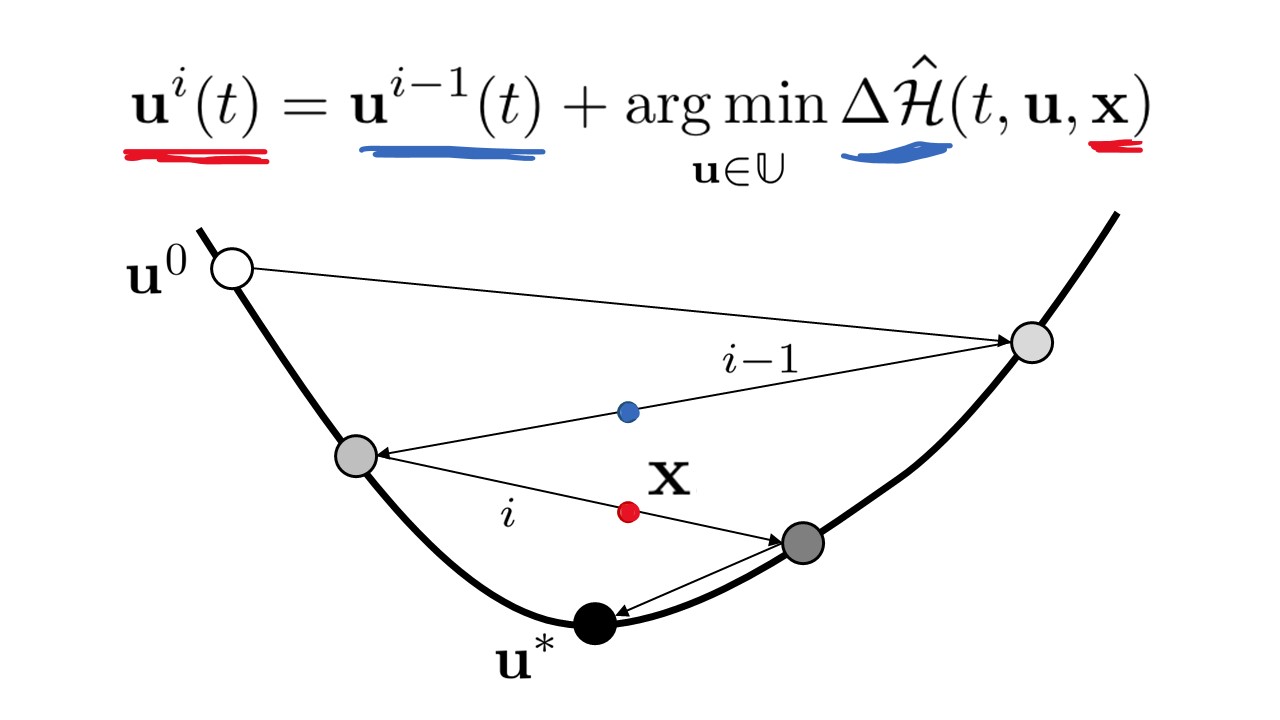
Highlights
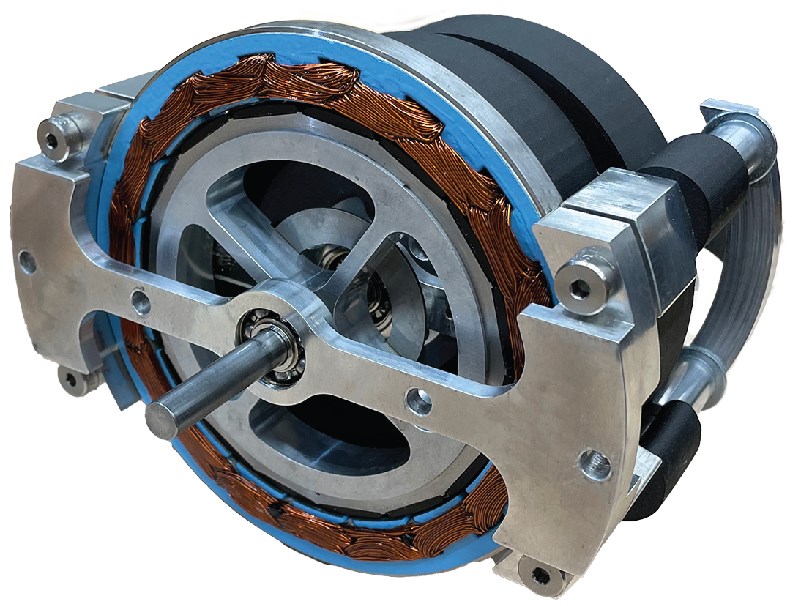
All news- U.S. Actuator Patent GrantedThe patent covers the parallel variable stiffness actuator: a direct-drive motor combined with a spring of adjustable stiffness, arranged in parallel. The design combines precise force control with efficient energy storage for robots and wearable devices. “Method and Apparatus for Human Augmentation and Robot Actuation,” U.S. Patent 12,275,145 B2, by D. Braun and C. Mathews.
- NSF CAREER AwardThis National Science Foundation CAREER Award supports research on mechanically adaptive robotics: robot actuators and wearable devices built around programmable springs. The stiffness of these springs can be changed to store and release energy as a task requires. The goal is a theoretical foundation for machines that enhance human physical abilities with little external energy.
- NSF CMMI/DCSD GrantThis National Science Foundation grant supports research on real-time optimal control by experiment. Instead of relying on uncertain model predictions, the robot improves the motion during physical experiments. An approximate model only speeds up the computation, and measured data guide each improvement.
- IEEE T-RO Best Paper AwardThe paper “Robots Driven by Compliant Actuators: Optimal Control under Actuation Constraints” received the 2013 King-Sun Fu Memorial IEEE Transactions on Robotics Best Paper Award, given each year to the best paper in the IEEE Transactions on Robotics. The award was presented at ICRA 2014 in Hong Kong. The paper shows how optimal control can exploit compliant actuators while safely respecting complex physical constraints: limits on actuator range, speed, and force. The method produced a human-like throwing motion without the use of human data.
Publications
All publicationsDesign and Control of a Parallel Elastic Actuator With Adjustable Equilibrium Position
Y. Chen, E. Chatziandreou, C. W. Mathews, B. P. Johnson and D. J. Braun
IEEE Robotics and Automation Letters, vol. 11, no. 6, pp. 6512–6519, 2026
@article{Chen2026,
  author  = {Y. Chen and E. Chatziandreou and C. W. Mathews and B. P. Johnson and D. J. Braun},
  title   = {Design and Control of a Parallel Elastic Actuator With Adjustable Equilibrium Position},
  journal = {IEEE Robotics and Automation Letters},
  volume  = {11},
  number  = {6},
  pages   = {6512--6519},
  year    = {2026},
  doi     = {10.1109/LRA.2026.3681100}
}
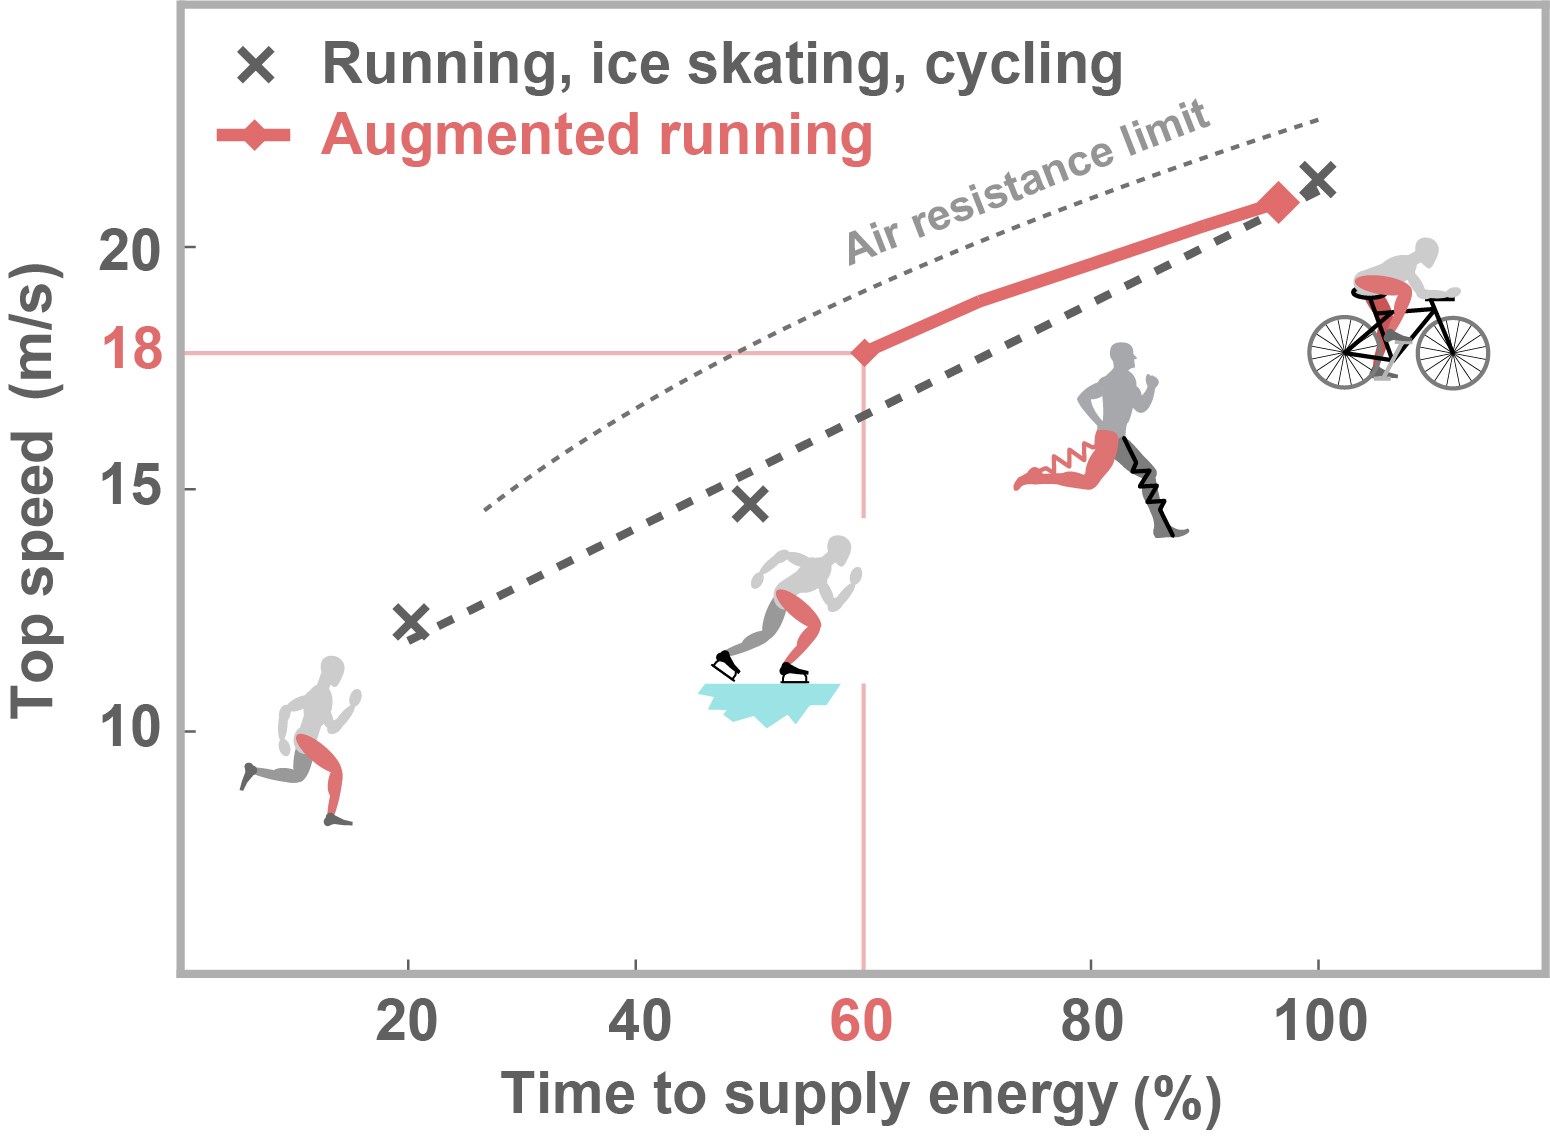
How to Run 50% Faster without External Energy
A. Sutrisno and D. J. Braun
Science Advances, vol. 6, no. 13, Art. no. eaay1950, 2020
@article{Sutrisno2020,
  author  = {A. Sutrisno and D. J. Braun},
  title   = {How to Run 50\% Faster without External Energy},
  journal = SA,
  volume  = {6},
  number  = {13},
  pages   = {eaay1950},
  year    = {2020},
  doi     = {10.1126/sciadv.aay1950}
}
Hardware-in-the-Loop Iterative Optimal Feedback Control without Model-Based Future Prediction
Y. Chen and D. J. Braun
IEEE Transactions on Robotics, vol. 35, no. 6, pp. 1419–1434, 2019
@article{Chen2019a,
  author  = {Y. Chen and D. J. Braun},
  title   = {Hardware-in-the-Loop Iterative Optimal Feedback Control without Model-Based Future Prediction},
  journal = IEEEtr,
  volume  = {35},
  number  = {6},
  pages   = {1419--1434},
  year    = {2019},
  doi     = {10.1109/TRO.2019.2929014}
}
Positive-Negative Stiffness Actuators
D. J. Braun, V. Chalvet and A. Dahiya
IEEE Transactions on Robotics, vol. 35, no. 1, pp. 162–173, 2019
@article{Braun2019b,
  author  = {D. J. Braun and V. Chalvet and A. Dahiya},
  title   = {Positive-Negative Stiffness Actuators},
  journal = IEEEtr,
  volume  = {35},
  number  = {1},
  pages   = {162--173},
  year    = {2019},
  doi     = {10.1109/TRO.2018.2872284}
}
Variable Stiffness Spring Actuators for Low Energy Cost Human Augmentation
D. J. Braun, V. Chalvet, T. H. Chong, S. S. Apte and N. Hogan
IEEE Transactions on Robotics, vol. 35, no. 6, pp. 1435–1449, 2019
@article{Braun2019a,
  author  = {D. J. Braun and V. Chalvet and T. H. Chong and S. S. Apte and N. Hogan},
  title   = {Variable Stiffness Spring Actuators for Low Energy Cost Human Augmentation},
  journal = IEEEtr,
  volume  = {35},
  number  = {6},
  pages   = {1435--1449},
  year    = {2019},
  doi     = {10.1109/TRO.2019.2929686}
}
Robots Driven by Compliant Actuators: Optimal Control under Actuation Constraints
D. J. Braun, F. Petit, F. Huber, S. Haddadin, P. van der Smagt, A. Albu-Schaffer and S. Vijayakumar
IEEE Transactions on Robotics, vol. 29, no. 5, pp. 1085–1101, 2013
2013 King-Sun Fu Memorial IEEE Transactions on Robotics Best Paper Award
@article{Braun2013,
  author  = {D. J. Braun and F. Petit and F. Huber and S. Haddadin and P. van der Smagt and A. Albu-Sch\"{a}ffer and S. Vijayakumar},
  title   = {Robots Driven by Compliant Actuators: Optimal Control under Actuation Constraints},
  journal = IEEEtr,
  volume  = {29},
  number  = {5},
  pages   = {1085--1101},
  year    = {2013},
  doi     = {10.1109/TRO.2013.2271099}
}