Publications

Robots Driven by Compliant Actuators: Optimal Control under Actuation Constraints

D. J. Braun, F. Petit, F. Huber, S. Haddadin, P. van der Smagt, A. Albu-Schaffer and S. Vijayakumar
IEEE Transactions on Robotics, vol. 29, no. 5, pp. 1085–1101, 2013
2013 King-Sun Fu Memorial IEEE Transactions on Robotics Best Paper Award
DOIVideo
@article{Braun2013,
  author  = {D. J. Braun and F. Petit and F. Huber and S. Haddadin and P. van der Smagt and A. Albu-Sch\"{a}ffer and S. Vijayakumar},
  title   = {Robots Driven by Compliant Actuators: Optimal Control under Actuation Constraints},
  journal = IEEEtr,
  volume  = {29},
  number  = {5},
  pages   = {1085--1101},
  year    = {2013},
  doi     = {10.1109/TRO.2013.2271099}
}

This paper presents an optimal control framework for robots driven by variable-impedance actuators, which can independently modulate torque and impedance. The method explicitly accounts for nonlinearities and real-world actuation limits, such as range, rate, and effort constraints. Through simulations and hardware experiments, the study demonstrates how optimized torque and stiffness profiles improve task performance while respecting practical actuator limitations.

Why it matters: Compliant actuators are essential for building robots with human-like agility and efficiency, but their nonlinear dynamics make control challenging. This award-winning work shows how to exploit their intrinsic capabilities while handling real-world constraints, advancing the practical control of anthropomorphic robots.
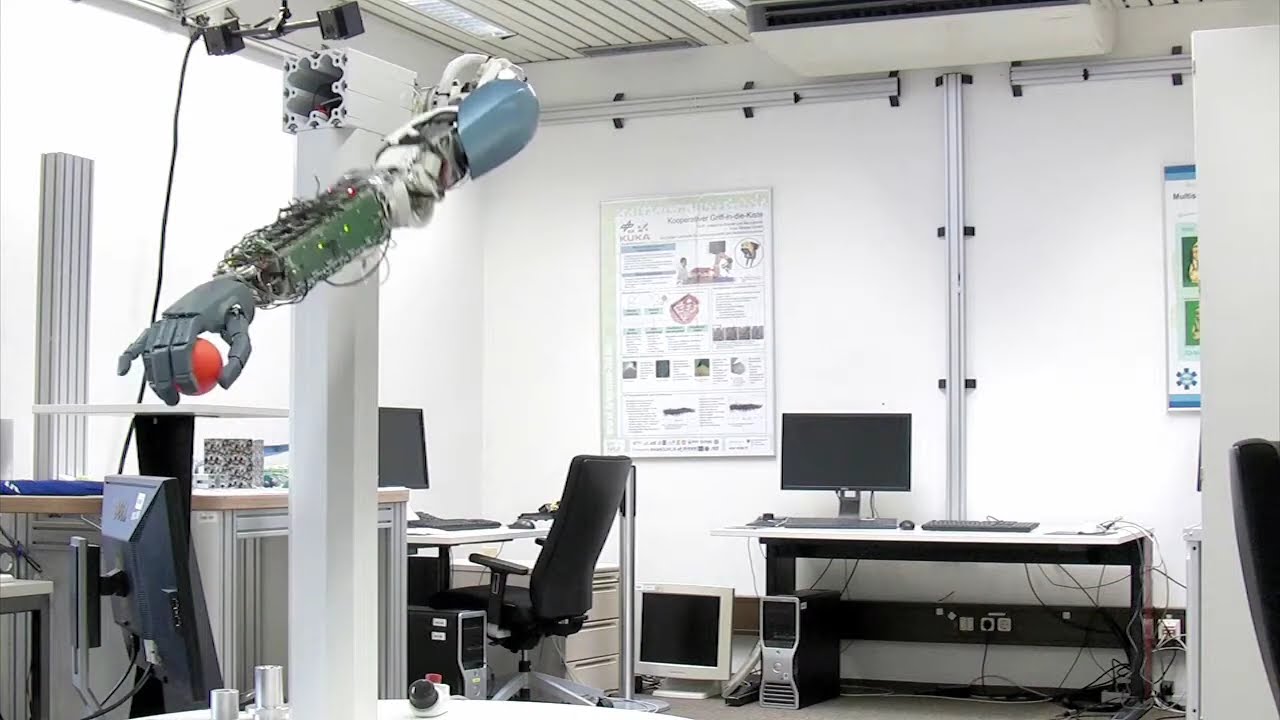
Video: Robots Driven by Compliant Actuators: Optimal Control under Actuation Constraints