Research
My research develops control methods and actuators for robots. On the control side, I combine models with data to compute optimal motions for robots in real time. On the actuator side, I design motors with springs of adjustable stiffness, so a robot can store and release energy as a task requires. Together, they let robots move with more capability and less energy.
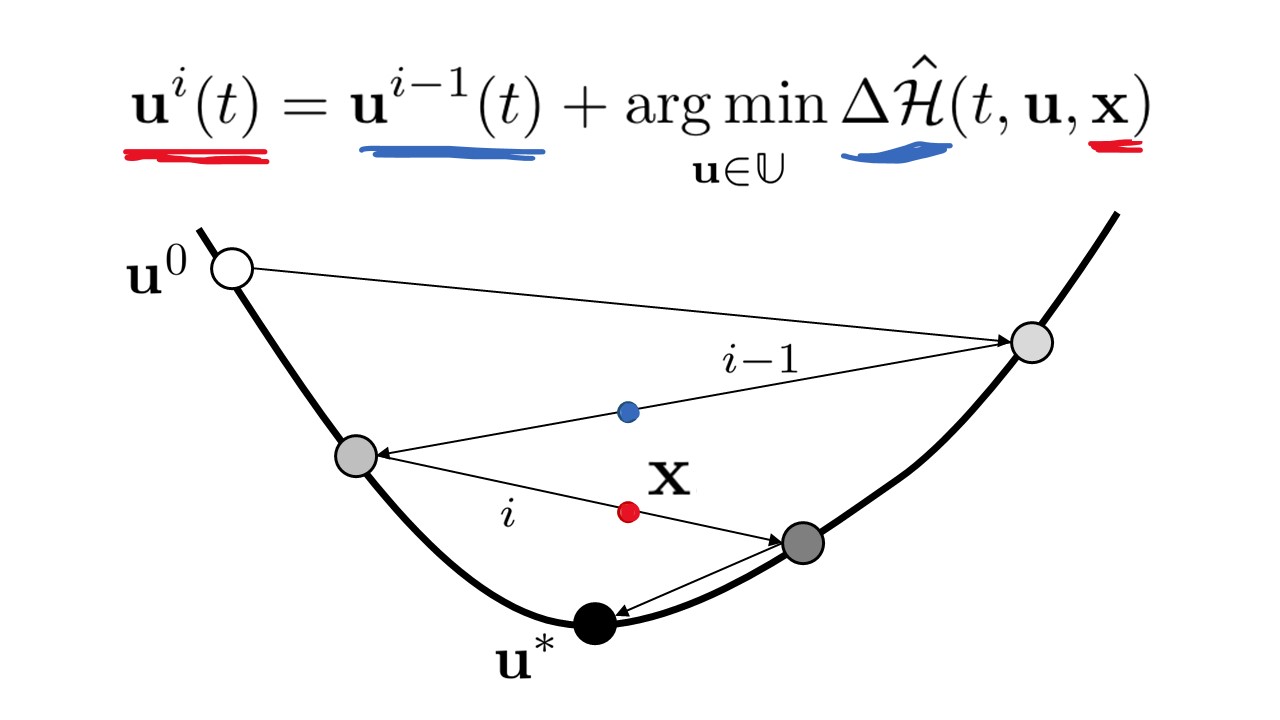
Real-time optimal control of robots
Optimal control computes the best possible motion for a robot, but the calculation relies on a model, and no model is exact. The motion that is optimal in simulation is therefore no longer optimal on the real machine: this is the sim-to-real gap. This research develops optimal control by experiment, in which the robot improves the motion during real experiments, so that measured data, not model predictions, decide how the robot moves.
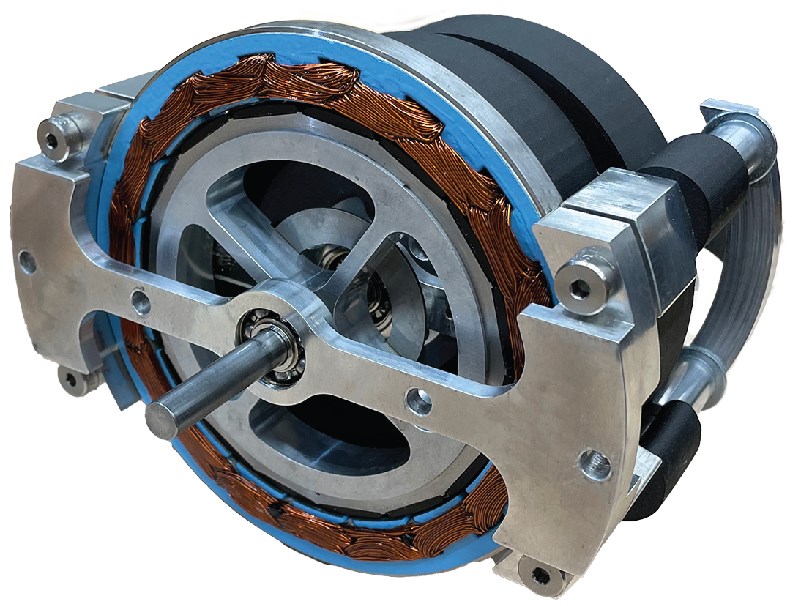
Mechanically adaptive actuators to advance robot autonomy
Actuators are the muscles of a robot. In the human body, muscles work together with tendons, which store and release energy. Compliant actuators bring the same idea to robots: springs are placed in series or in parallel with the motors. The most common types are series elastic actuators (SEAs) and variable stiffness actuators (VSAs). This research develops new types of compliant actuators that adapt their mechanics to the task.
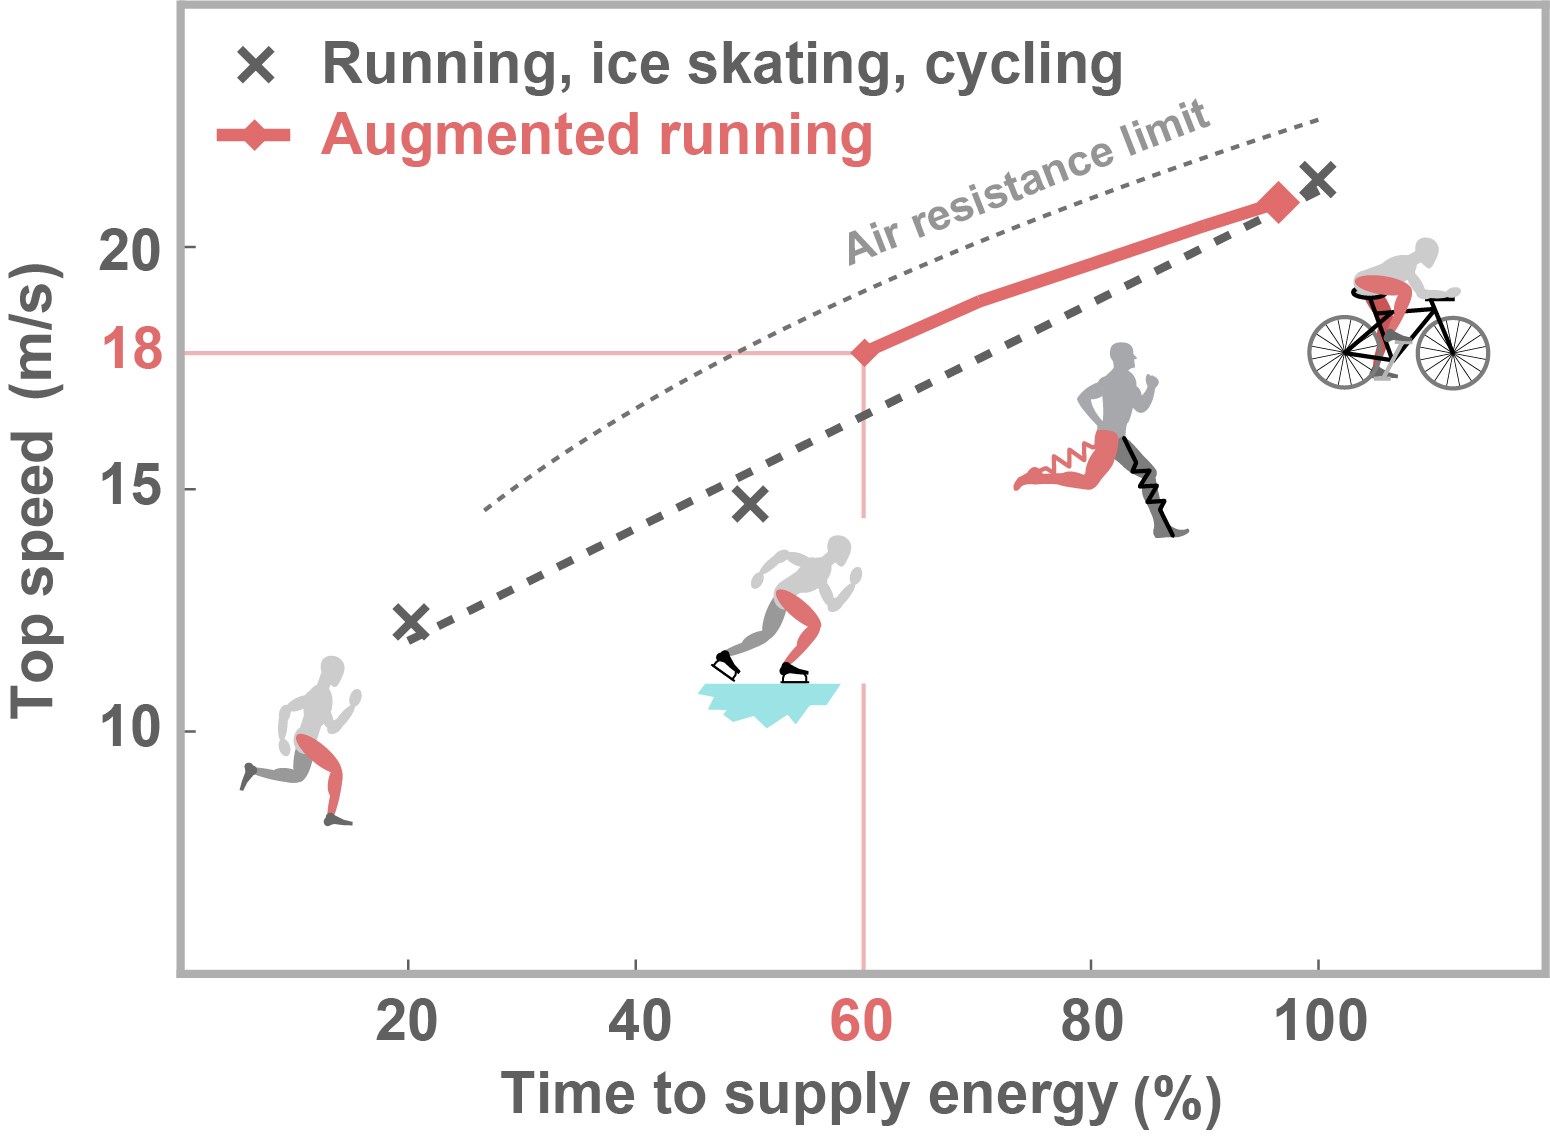
Mechanically adaptive robot exoskeletons to improve human mobility
A bicycle has no motor, yet a person on a bicycle travels much farther and faster than on foot. This research develops the theory of robot exoskeletons that work in the same spirit: unpowered devices, or devices driven by small actuators such as a small electric motor, that give a person capabilities beyond those of an unassisted human, to an extent previously thought to require large powered actuators.
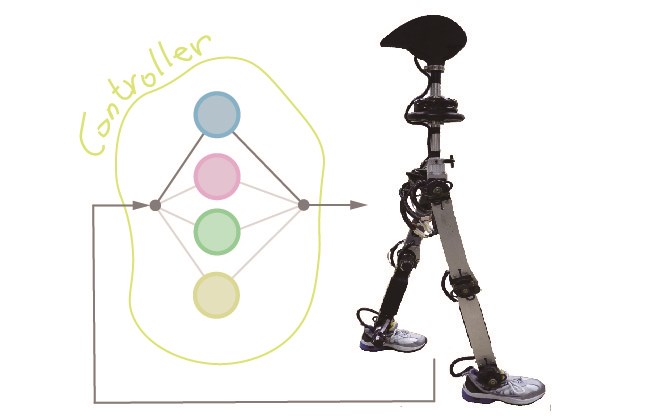
Reverse-engineering nature for locomotion control in robots
Walking looks effortless, yet every step requires the nervous system to coordinate the legs and keep the body balanced at the same time. Understanding how humans do this is a first step toward robots that assist and augment people, such as exoskeletons for rescue operations or for people whose walking is impaired by illness or injury. This research develops simplified models of the biological controller behind human walking, and uses them to control walking robots and assistive devices.
Physics-based numerical simulation methods for predicting robot behavior
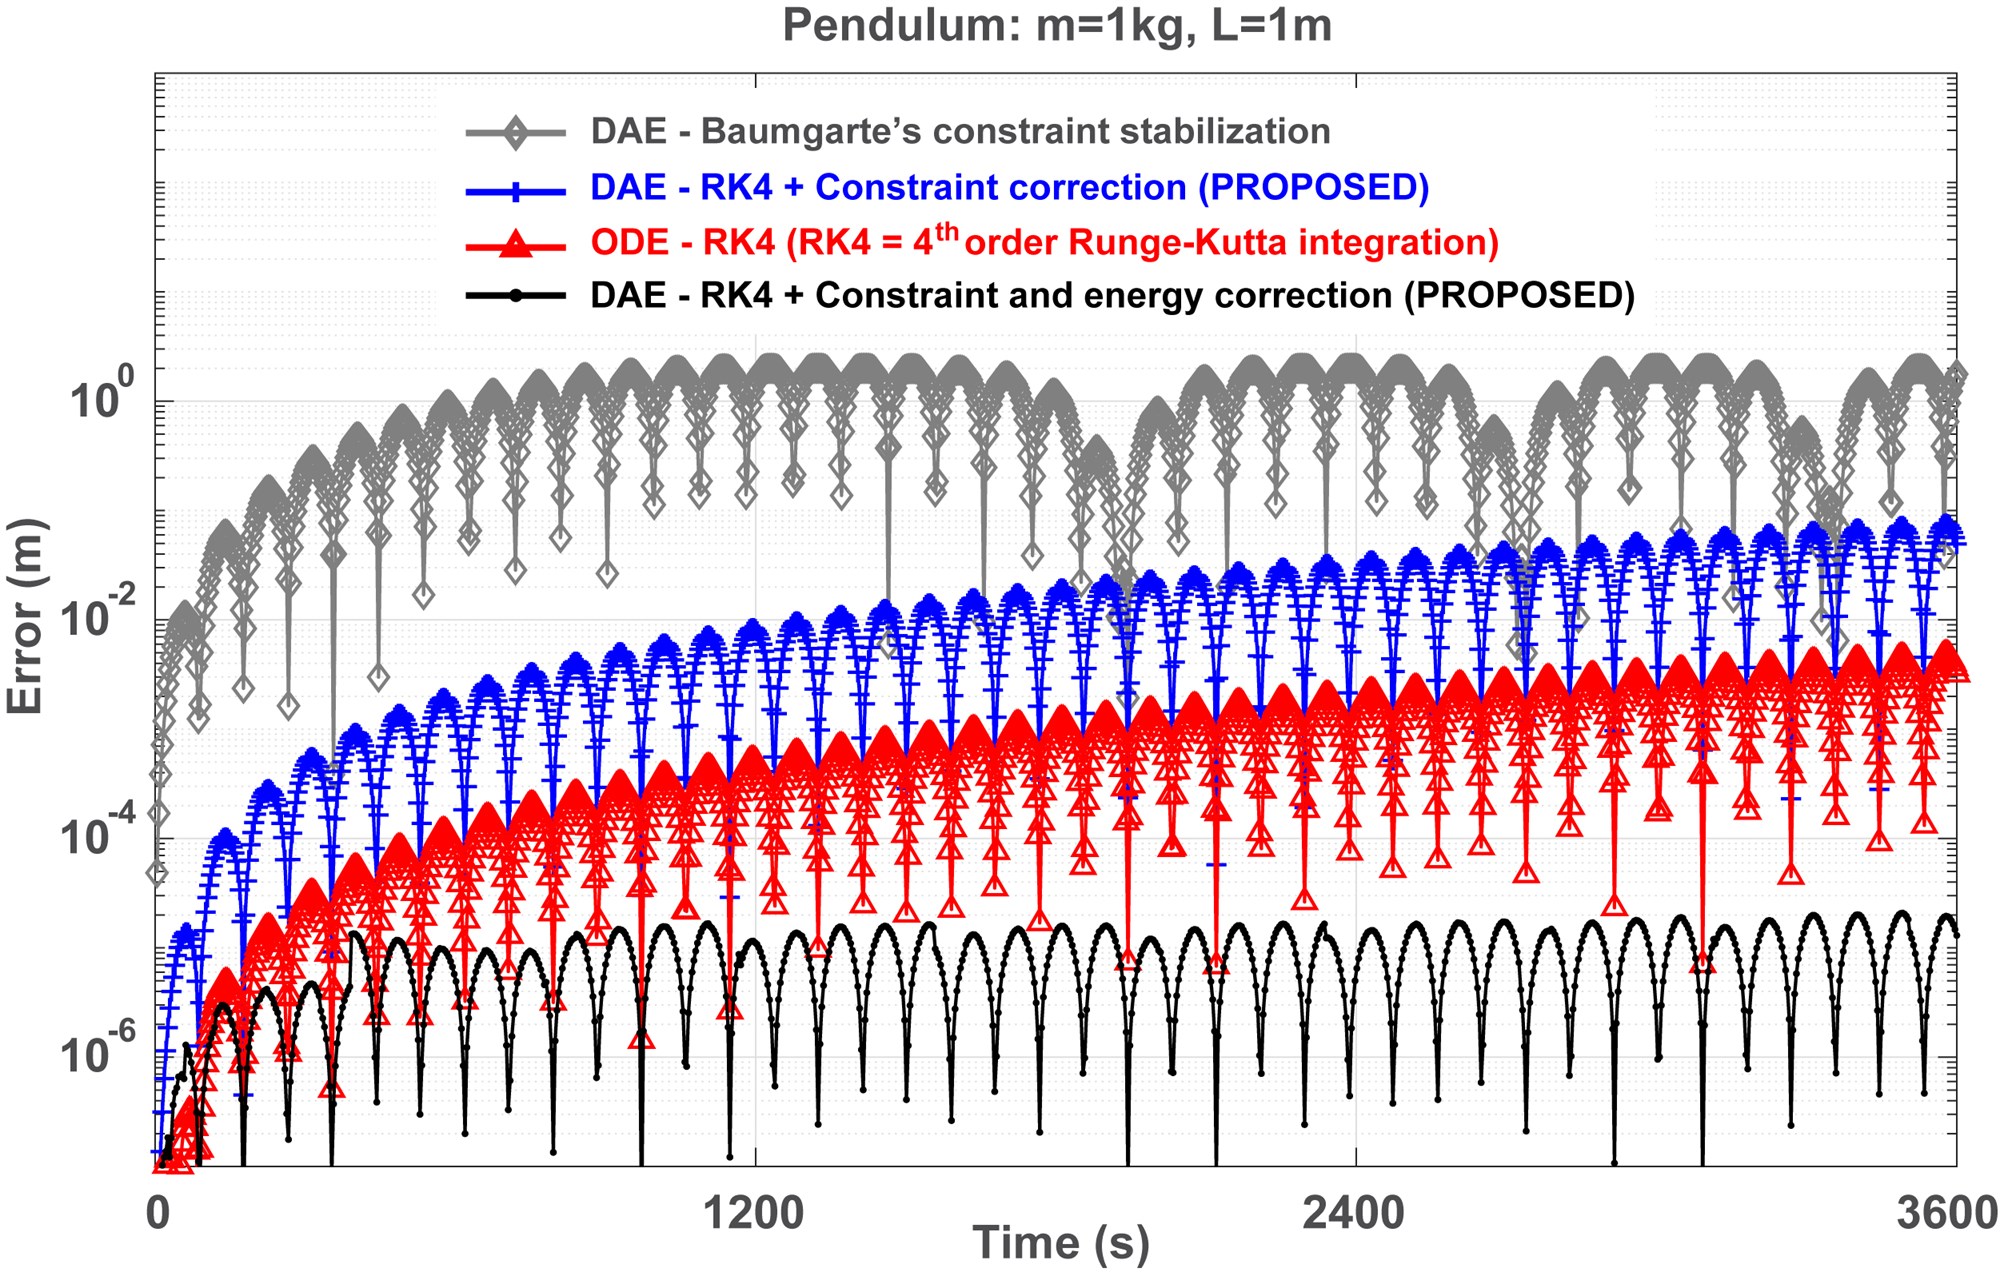
A walking robot is constrained by the ground: each foot can push against the ground but cannot pass through it, and the constraints change every time a foot lands or lifts off. Robots like this are constrained dynamical systems, described by differential equations together with holonomic and non-holonomic (algebraic) constraints. One way to model them is with switching differential-algebraic equations (SDAEs): a set of differential equations combined with a switching set of algebraic constraints. This approximates unilaterally constrained, non-holonomic systems with piecewise holonomic systems. This research develops numerical simulators that solve differential-algebraic equations efficiently, to predict robot motion accurately and to support the design of better controllers.