Publications

Stiffness Modulator: A Novel Actuator for Human Augmentation

H. F. Lau, A. Sutrisno, T. H. Chong and D. J. Braun
IEEE International Conference on Robotics and Automation, pp. 7742–7748, 2018
@inproceedings{Lau2018conf,
  author    = {H. F. Lau and A. Sutrisno and T. H. Chong and D. J. Braun},
  title     = {Stiffness Modulator: A Novel Actuator for Human Augmentation},
  booktitle = {IEEE International Conference on Robotics and Automation},
  pages     = {7742--7748},
  address   = {Brisbane, Australia},
  month     = {May},
  year      = {2018},
  doi       = {10.1109/ICRA.2018.8463186}
}

This paper introduces a compact and lightweight stiffness modulator that provides stiffness adjustment without performing deliberate mechanical work. Designed for human augmentation, the device complements natural muscle co-contraction to reduce muscle activity and metabolic cost. Experiments demonstrate its ability to augment the human knee joint during a sit-to-stand task, showing reduced muscle effort while consuming minimal battery power.

Why it matters: Portable stiffness modulation has long been a challenge for human augmentation. This work demonstrates a practical implementation that can support everyday movements efficiently, opening the door to wearable devices that enhance mobility while conserving energy.
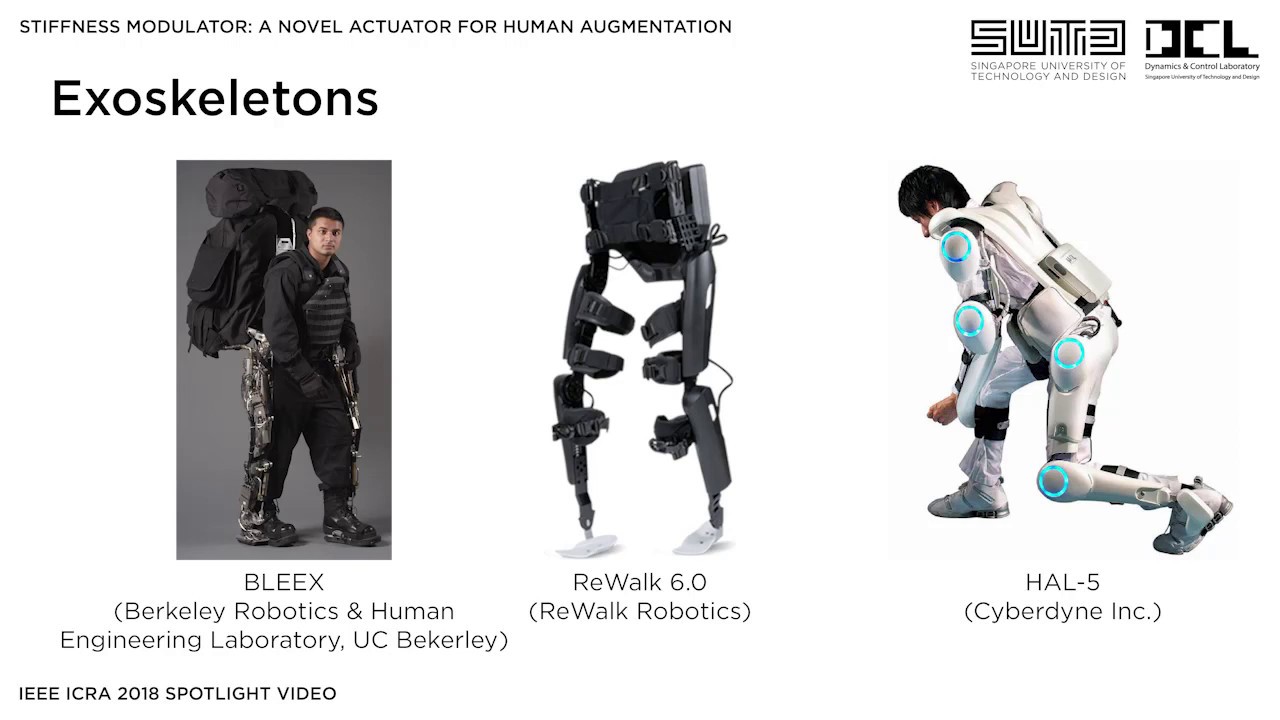
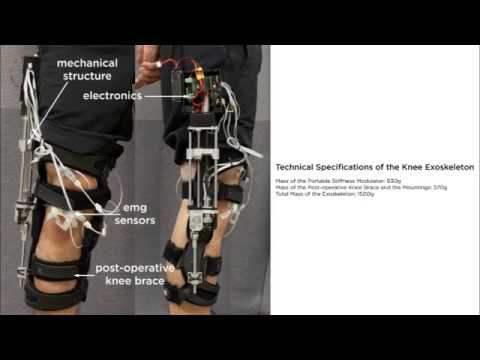
Video: Stiffness Modulator: A Novel Actuator for Human Augmentation