Optimization and Optimal Control
About the course
Optimization and optimal control are essential tools for designing systems that minimize cost, time, or resources. These methods provide a systematic approach to decision-making in engineering and science, with applications ranging from fuel-efficient spacecraft trajectories and real-time energy optimization in robotics to the training of machine learning models. The course connected these mathematical principles with real-world applications, bridging theory and practice.
My expertise
I specialize in optimization and optimal control, focusing on both theoretical foundations and computational methods related to:
- Nonlinear Programming: Techniques for solving static optimization problems—minimizing functions subject to constraints.
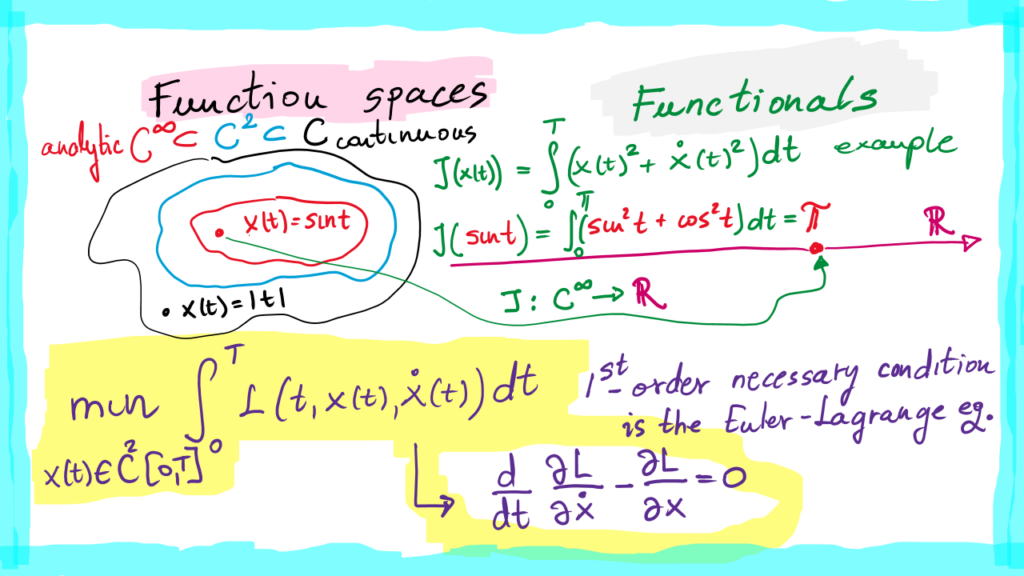
- Calculus of Variations: Methods for solving dynamic optimization problems—minimizing functionals subject to constraints.
- Optimal Control:
- Pontryagin’s Maximum Principle: A powerful framework to solve optimal control problems and determine feedforward control inputs.
- Dynamic Programming: A general framework to solve optimal control problems and derive feedback control laws or control policies.
Teaching approach
The teaching made complex concepts in optimization and control accessible and engaging, through:
- Step-by-Step Progression: From simple, familiar problems, such as minimizing a quadratic function, to more complex ones.
- Interactive Learning: Encouraging active participation, from hands-on MATLAB coding to solving real-world engineering problems.
- Bridging Disciplines: Linking optimization to applications in robotics, aerospace, and mechanics for a holistic understanding.
Why study optimization and optimal control?
Every engineering challenge ultimately involves making decisions—how to allocate resources, how to design efficient systems, and how to control them in real time. Optimization is the language that enables us to make these decisions systematically.
Consider a simple problem: if you are launching a spacecraft, should you aim for the shortest path or the most energy-efficient trajectory? The naive answer might be to take a direct route, but an optimal control perspective would reveal trade-offs between fuel, time, and orbital mechanics that must be mathematically optimized. The same principles apply whether you are designing an autonomous drone, optimizing neural network hyperparameters, or developing an exoskeleton to enhance human mobility.
Optimization is not about guessing or intuition—it is about constructing solutions with mathematical precision and algorithmic efficiency.