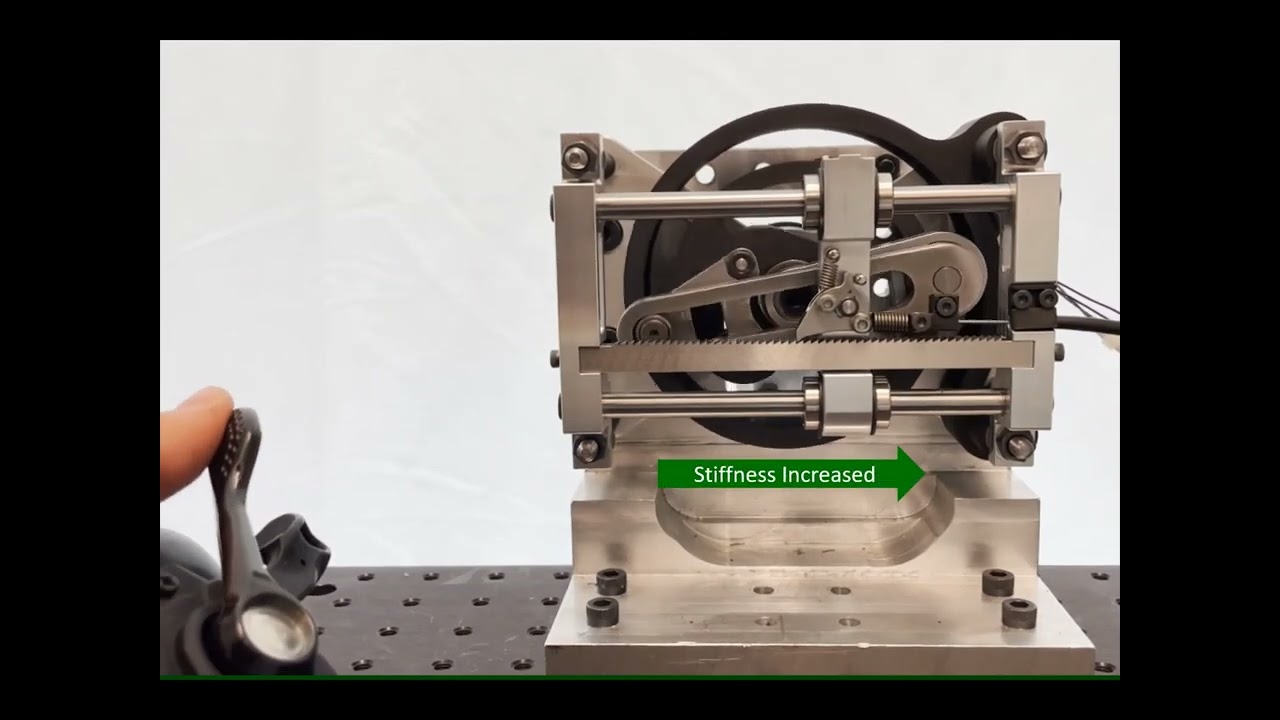
This paper introduces a variable stiffness spring that allows users to manually adjust stiffness, similar to changing gears on a bicycle. The spring enables individuals to increase or decrease assistive torque depending on the task or user needs. In leg-swing experiments, participants successfully tuned stiffness across a wide range to assist the hip joint during oscillatory motion.
Why it matters: Different activities and users require different levels of assistance, but traditional springs offer fixed stiffness. A human-selectable variable stiffness spring provides a simple, adaptable way to support diverse locomotion tasks such as walking, running, swimming, or lifting, making wearable devices more versatile and user-centered.