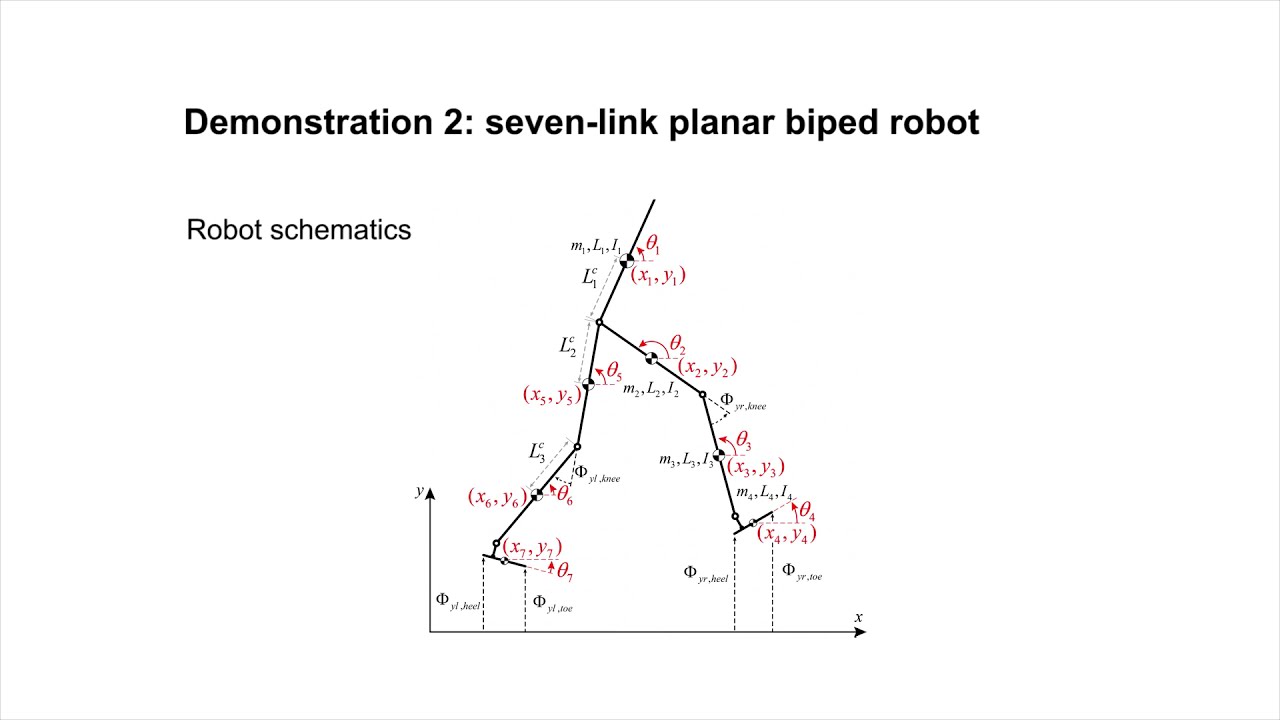
This paper presents a differential–algebraic formulation for modeling non-smooth robot dynamics involving switching constraints and multiple impacts. The method integrates a unified governing equation, switching kinematic constraints, and the plastic impact law. Its key contribution is a new algorithmic approach that explicitly resolves multiple simultaneous impacts, replacing traditional iterative complementarity-based methods. The approach is validated through simulations of biped locomotion.
Why it matters: Robots frequently interact with their environment through impacts, which are difficult to model and simulate efficiently. This work provides a simple and explicit framework for resolving multiple impacts, improving the accuracy and computational efficiency of simulations in locomotion and contact-rich robotics.