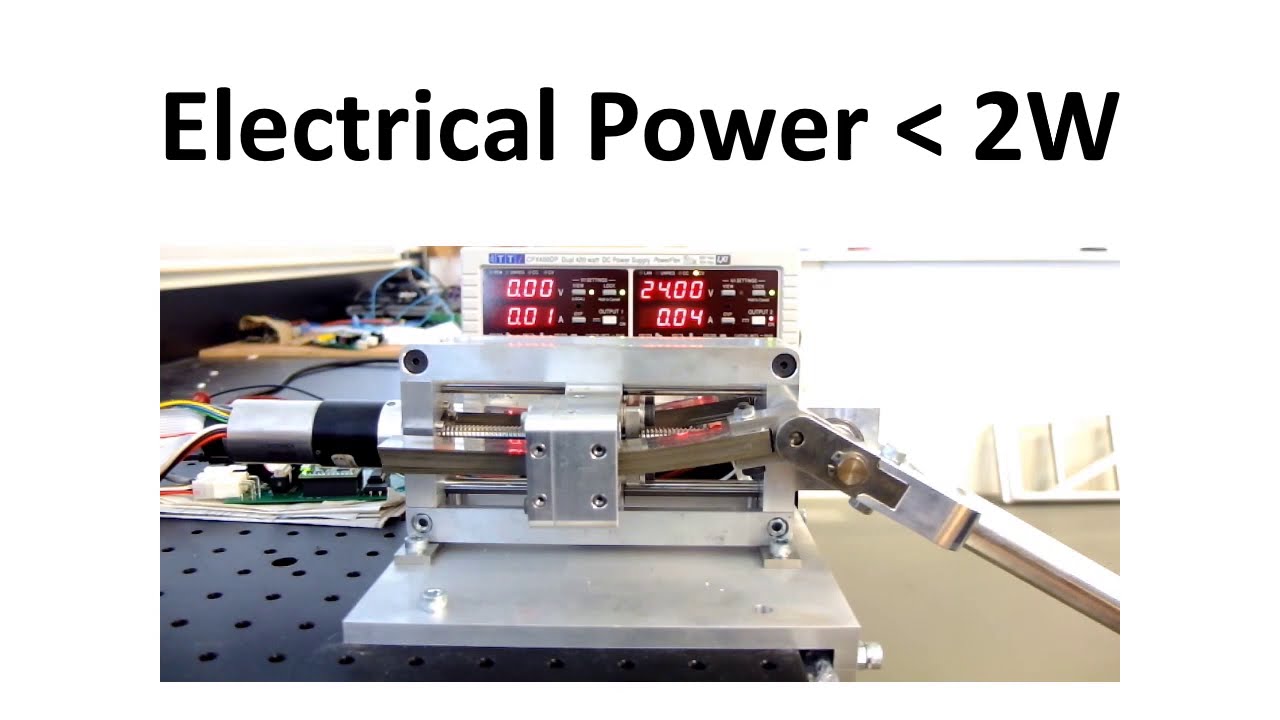
This paper presents an optimization-based framework for designing compliant mechanisms that enable low-power stiffness adaptation. The approach formulates the design process as a constrained nonlinear parameter optimization problem, allowing systematic identification of mechanisms that minimize power requirements. The framework also supports comparisons across different kinematic topologies to determine the most efficient designs.
Why it matters: Variable stiffness mechanisms are essential for the next generation of energy-efficient robotic systems, but their design has often relied on intuition and trial-and-error. This work provides a rigorous, algorithmic method to create intrinsically low-power designs, accelerating the development of advanced actuators for robotics and human augmentation.