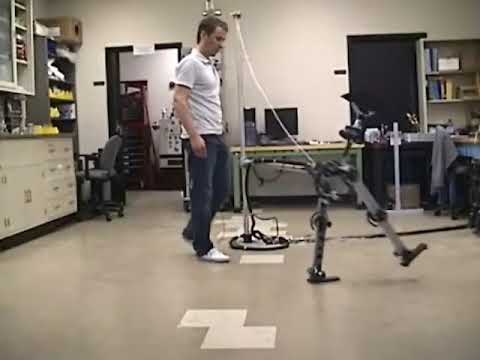
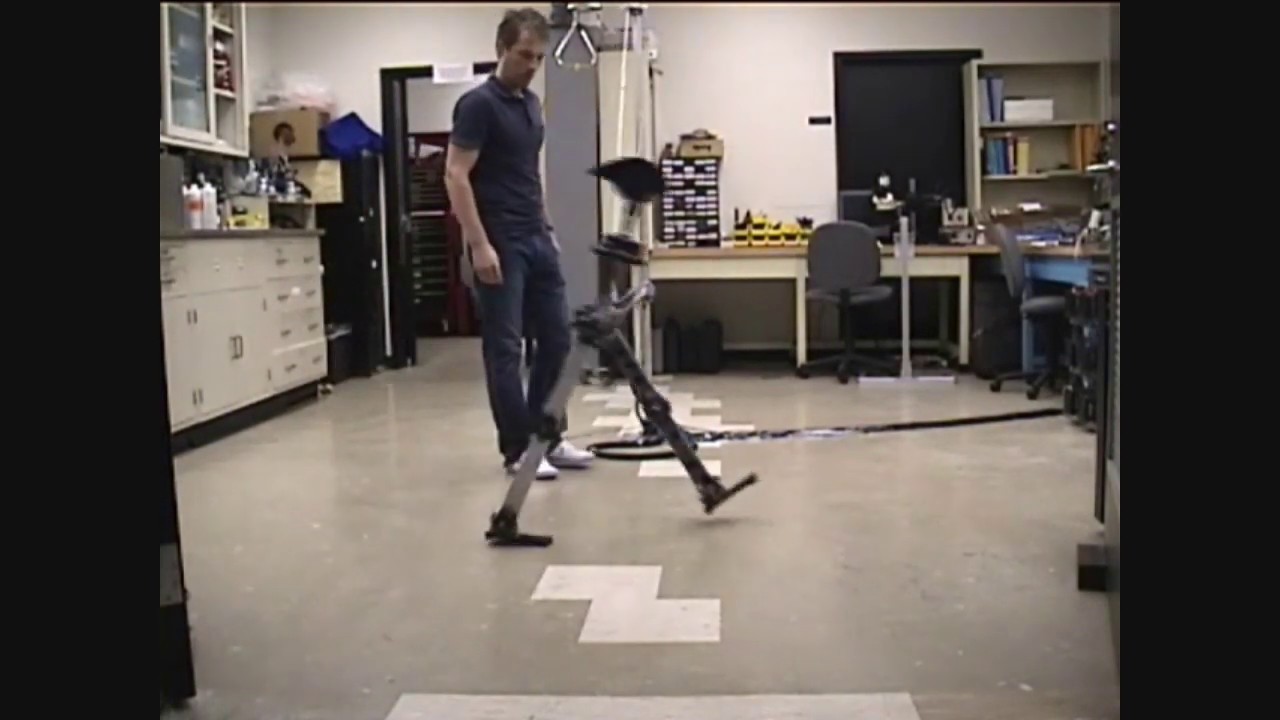
This paper presents experimental validation of a control method for bipedal walking that does not rely on joint trajectory tracking or kinematic constraints. Implemented on a custom seven-link biped robot, the method produces a “relaxed” style of walking and achieves efficient locomotion. Experimental results demonstrate both the natural appearance of the gait and competitive mechanical cost of transport compared to reported benchmarks.
Why it matters: Conventional biped control often enforces precise trajectories, leading to rigid, inefficient gaits. This work shows that alternative control strategies can yield more natural and energy-efficient walking, offering insights for the design of humanoid robots and wearable robotics.