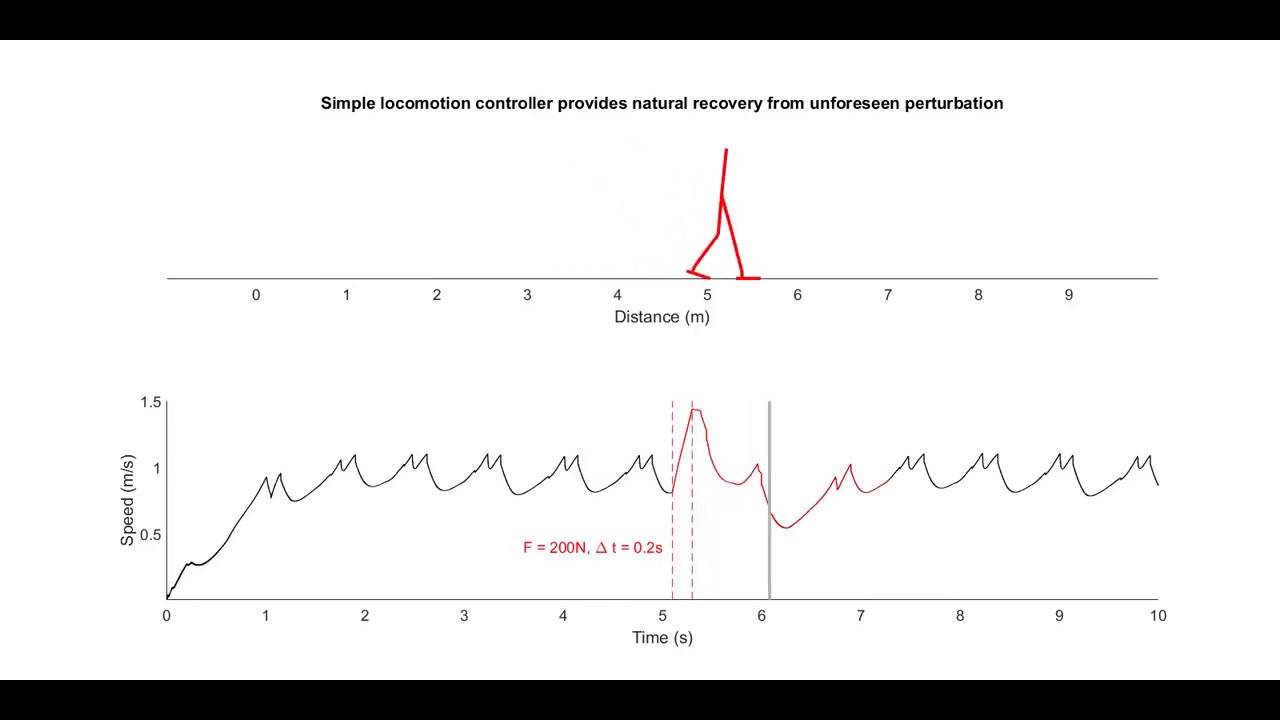
This paper presents a closed-loop control method for fully actuated biped robots that leverages natural system dynamics rather than prescribing joint trajectories. The approach uses state-dependent torques constructed from low-gain spring-damper elements, allowing limb motion to emerge from the interaction of passive control components and the robot’s natural dynamics. Simulations show the method produces stable, natural-looking walking across a range of initial conditions, speeds, and ground slopes, while achieving significantly lower mechanical cost of transport compared to trajectory-tracking approaches. The controller also demonstrates robustness to disturbances and model uncertainty.
Why it matters: Most biped controllers enforce rigid trajectory tracking, which limits efficiency and adaptability. This work demonstrates that exploiting natural dynamics leads to more efficient, stable, and robust walking, laying a foundation for energy-efficient humanoid robots and informing the design of wearable robotics.